Joint Shaft Precision Cylindrical Grinding: Enabling Humanoid Robot Agility
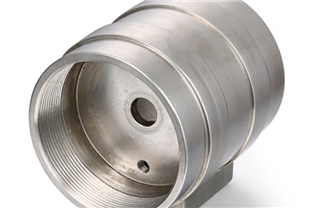
Date:2026-09-08Article editor:Starting Point PrecisionViews:149Humanoid robots rely on dozens of actuated joints—each requiring shafts with extreme roundness, surface finish, and dimensional consistency. These components transfer torque, support radial loads, and enable smooth articulation. Cylindrical grinding remains the final, non-negotiable finishing operation that transforms hardened steel blanks into high‑reliability shafts. This article outlines the process, equipment, and proven practices for manufacturing joint shafts that meet the exacting standards of modern robotics.
Why Cylindrical Grinding for Robot Joints?
● Tight tolerances: Typical shaft diameters must hold ±2 µm, with roundness below 1 µm.
● Surface integrity: Ra < 0.2 µm reduces friction and wear in high‑cycle articulations.
● Geometric stability: Straightness and taper are critical for press‑fit assemblies and bearing interfaces.
● Material versatility: Handles hardened alloys (e.g., 440C, 17‑4PH, Inconel 718) with consistent results.
Key Process Parameters & Control
| Parameter | Range / Value | Impact on Shaft Quality |
| Wheel speed (Al₂O₃/CBN) | 45 – 63 m/s | Higher speed improves finish but increases heat |
| Workpiece speed | 0.5 – 2.0 m/min | Balances cycle time and chatter suppression |
| Depth of cut (roughing) | 0.02 – 0.05 mm | Removes stock efficiently while preserving form |
| Depth of cut (finishing) | 0.002 – 0.008 mm | Ensures final roundness and low roughness |
| Coolant pressure & flow | 20 – 40 bar, 50 L/min | Flushes swarf and stabilises thermal growth |
| Dressing interval | Every 5 – 10 parts | Maintains wheel sharpness and cutting geometry |
These parameters are tailored per shaft length‑to‑diameter ratio and material hardness. In‑process gauging (air‑or‑electronic) provides closed‑loop compensation, reducing rejections to < 0.5%.
Precision Equipment for High‑Volume Shaft Production
Based on the Precision equipment list at Start Precision, the following cylindrical grinding assets are deployed for robot joint shafts:
| Equipment | Brand / Model | Key Specification | Application |
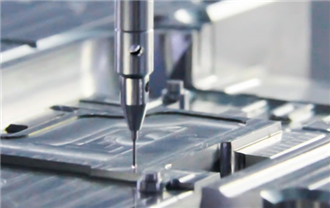
| Top inner & outer round grinder | Glory GU32‑60NC (Taiwan) | Max. swing Ø320 mm, between centres 600 mm, roundness ≤ 0.0015 mm | External & internal diameters, stepped shafts |
| Centreless grinder | Glory 12C | Capacity Ø2 – 50 mm, straightness ≤ 1 µm / 100 mm | High‑volume through‑feed for pin‑type joints |
| Flat profile grinder | MICCO 350 | Table travel 350 mm, precision feed 0.001 mm | Complex end‑faces and shoulder radii |
All machines are fitted with in‑process sizing and acoustic emission sensors to detect wheel contact, ensuring consistent cycle times and dimensional stability across batches.
Process Sequence for a Typical Humanoid Shoulder Shaft
1. Rough turning – leaves 0.15 – 0.20 mm stock.
2. Heat treatment – to 52 – 58 HRC.
3. Centre grinding – establishes accurate centres for subsequent operations.
4. Rough cylindrical grinding – removes 70% of stock using a coarse‑grit Al₂O₃ wheel.
5. Finish cylindrical grinding – uses a fine‑grit CBN wheel with multiple spark‑out passes to achieve final geometry.
6. Superfinishing (optional) – reduces Ra to 0.05 µm for critical sealing surfaces.
During finish grinding, a coolant‑through‑spindle system maintains thermal stability, while a Marposs gauge actively measures diameter and triggers automatic compensation for wheel wear.
Case Example: 6‑Axis Robot Arm Joint Shaft
Requirement:
● Diameter: 25.000 ± 0.002 mm
● Roundness: 0.0012 mm
● Straightness over 120 mm: 0.002 mm
● Surface roughness: Ra 0.16 µm
● Material: AISI 4340 hardened to 55 HRC
● Batch size: 2,000 pcs/month
Approach & Results:
Using the Glory GU32‑60NC with a 480 mm × 50 mm CBN wheel, the process achieved a cycle time of 4.2 minutes per shaft (including loading and gauging). After 50 parts, wheel dressing restored aggressive cutting, and the Cpk value remained above 1.67 for all critical dimensions. Rejection rate was 0.3%—entirely attributed to incoming material anomalies.
In‑Factory Capabilities & Quality Assurance
At Start Precision, we maintain a climate‑controlled grinding cell (20 ± 0.5 °C) to eliminate thermal expansion errors. Our quality system includes:
● Mitutoyo roundness tester for every batch sample
● Taylor Hobson profilometer for surface finish verification
● ISO 9001:2015 and IATF 16949 certified processes
Our team has successfully delivered over 150,000 precision shafts for collaborative robots, exoskeletons, and industrial manipulators. We continuously invest in advanced grinding technologies and operator training to push the boundaries of accuracy and productivity.
Proven Results – A Recent Delivery
For a leading humanoid robotics developer, we ground 5,000 shafts with the following specifications:
● Diameter 12.7 mm, length 85 mm
● Taper < 1 µm over full length
● Batch‑to‑batch consistency within ±1.5 µm
Using the Glory GU32‑60NC and a custom work‑holding solution, we reduced cycle time by 18% compared to previous suppliers. The customer reported a 30% reduction in bearing noise attributed to improved roundness and surface texture. This real‑world success confirms that meticulous cylindrical grinding directly enhances robot dynamic performance and lifespan.
Contact Us to Discuss Your Manufacturing Requirements
Whether you are developing prototype joints or scaling to mass production, our grinding expertise and modern equipment fleet are ready to support your project. We welcome inquiries about process development, sample runs, and capacity planning. Reach out to our engineering team for a technical consultation.
Start Precision – Where accuracy meets reliability.
Visit our homepage for an overview of our capabilities, or explore our complete equipment list to see the full range of machining resources.
Frequently Asked Questions
Q1: What is the typical tolerance for humanoid robot joint shafts?
A: Diameter tolerances commonly range from ±1 µm to ±3 µm, with roundness below 1 µm and surface roughness Ra < 0.2 µm to ensure low friction and long bearing life.
Q2: How does cylindrical grinding compare to hard turning or honing?
A: Cylindrical grinding provides superior roundness and surface finish for hardened materials, while hard turning is faster but leaves residual stresses. Honing improves bore finishes but is less effective for external diameters. Grinding remains the preferred choice for critical rotary shafts.
Q3: What materials are commonly ground for robot components?
A: Stainless steels (e.g., 440C, 17‑4PH), alloy steels (e.g., 4140, 4340), and some titanium alloys are common. CBN wheels are preferred for hard steels above 50 HRC.
Q4: How can I ensure consistent quality in mass production?
A: Employ in‑process gauging, regular wheel dressing, stable coolant temperature, and routine calibration of measuring instruments. Statistical process control (SPC) and Cpk monitoring are essential to detect drifts early.
Q5: Do you offer prototyping and small‑batch services?
A: Yes, we support all volumes from single‑piece prototypes to high‑volume production runs, with dedicated setup and inspection reports for each lot.
Add: Building 3No.277 Zhen'an Middle Road, Chang'an Town,Dongguan,Guangdong, China
Tel:+86-769-82855591
Copyright © 2019 All Rights Reserved Dongguan Start Precision Technology Co., Ltd. Tel: +86-769-82855591
Add: No. 277 Zhen'an Middle Road, Chang'an Town, Dongguan, Guangdong, China
 中文版
 English